Erica
Price
Price not publicly disclosed
No defensible public pricing observation is documented yet.
Key facts
Values reflect the public record
- Height
- 166 cmThird-party source
- Weight
- 23 kg
- Payload
- No public data documented
- Degrees of freedom
- 44Peer reviewed
- Runtime
- No public data documented
- Max speed
- No public data documented
Canonical robot record
Overview
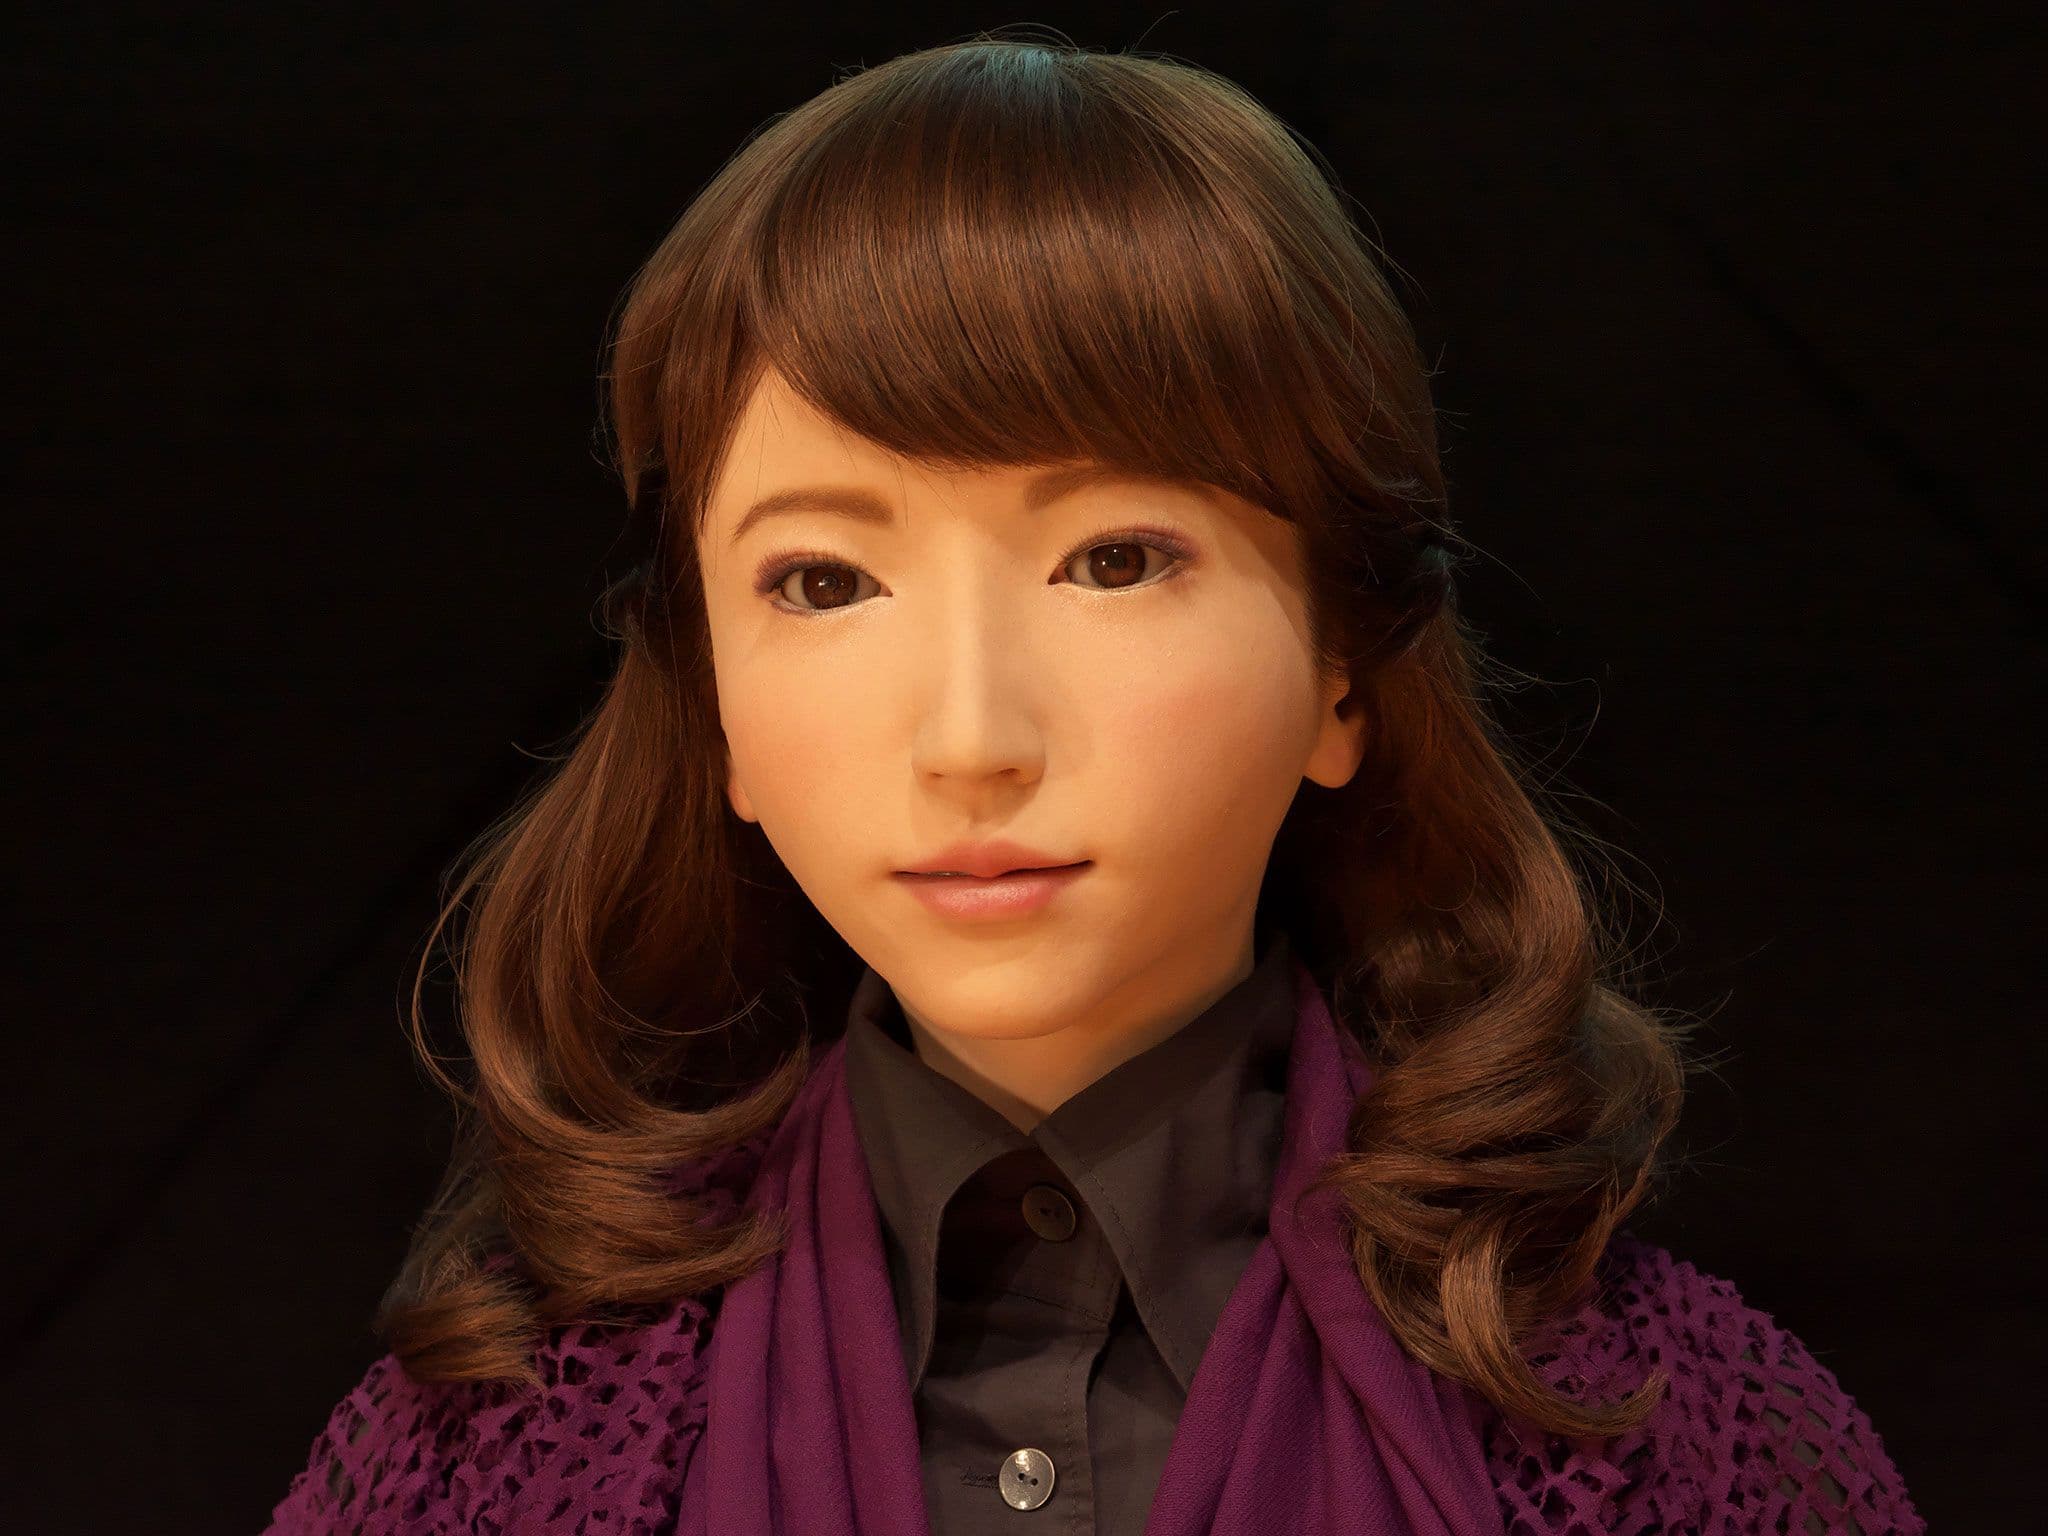
Erica, short for ERATO Intelligent Conversational Android, is an autonomous android created within the JST/ERATO Ishiguro Symbiotic Human-Robot Interaction Project, a collaboration among Hiroshi Ishiguro Laboratories at ATR, Osaka University, and Kyoto University in Japan. She is built as a research and development platform for autonomous conversational robots that can communicate through voice, bodily gestures, facial expressions, eye contact, and touch. Her appearance was designed for a natural, approachable look, with silicone-resin skin and a human-hair wig, and she speaks using high-quality speech synthesis. The project goal is to realize androids that can naturally interact with people and be socially involved in everyday life.
RoboZaps maintains this record as part of its canonical robotics database. Specs are source-verified where linked; the record compares public facts across manufacturers rather than representing a single robot maker.
- Spec sources
- 2 linked
- Verification
- Partially verified · 4/6 specs source-verified
- Deployment
- Research platform
- Last verified
- Jul 17, 2026
Key Features
- Autonomous conversational interaction using voice recognition and high-quality speech synthesis
- Pneumatic actuators that drive smooth, low-noise body movement
- Multimodal sensing system with cameras, microphones, and a microphone array to recognize people, speech, and speaker position
- Human-like facial expressions, gestures, and eye contact for natural communication
- Realistic appearance with silicone-resin skin and a human-hair wig
- Operated as a research and development platform within the JST/ERATO Ishiguro project
Specifications
Grouped technical data with source detail available on demand.
6 documented values
Mechanics
| Degrees of Freedom | 44Peer reviewedVerified Jul 10, 2026 IEEE RO-MAN 2016 (Glas et al.) |
|---|---|
| Locomotion | StationaryPeer reviewedVerified Jul 10, 2026 IEEE RO-MAN 2016 (Glas et al.) |
| Actuators | Pneumatic actuators Unverified |
Physical
| Height | 166 cmThird-party sourceVerified Jul 10, 2026 IEEE Robots Guide |
|---|---|
| Weight | 23 kg Unverified |
Sensing
| Sensors | 2 CMOS cameras (eyes), 2 microphones (ears); external microphone arrays and range findersPeer reviewedVerified Jul 10, 2026 IEEE RO-MAN 2016 (Glas et al.) |
|---|
Evidence & changelog
Sources behind this record and material corrections made over time.
Sources
- IEEE RO-MAN 2016 (Glas et al.) - record-surgery-3 verification · IEEE RO-MAN 2016 (Glas et al.) — cites Degrees of Freedom, Sensors, Locomotion
- IEEE Robots Guide - record-surgery-3 verification · IEEE Robots Guide — cites Height
Media
Manufacturer
- Headquarters
- No public data documented
- Founded
- No public data documented
- Website
- No public data documented